Drone motor speed control with an Arduino Nano, a pot and an ESC
Turn a knob and a drone motor's propeller speeds up from 0 to 100 % throttle, then slows back down.
- 6 parts
- 5 wiring steps
- Arduino code
Quick answer
The short version. Every pin is in the full wiring below.What you need
- 2212 1000KV brushless outrunner motor
- 10 inch two-blade propeller
- 30 A ESC with a 5 V BEC
- 3S 2200 mAh 25C LiPo battery
- Arduino Nano
- 10 k linear potentiometer
How to wire it
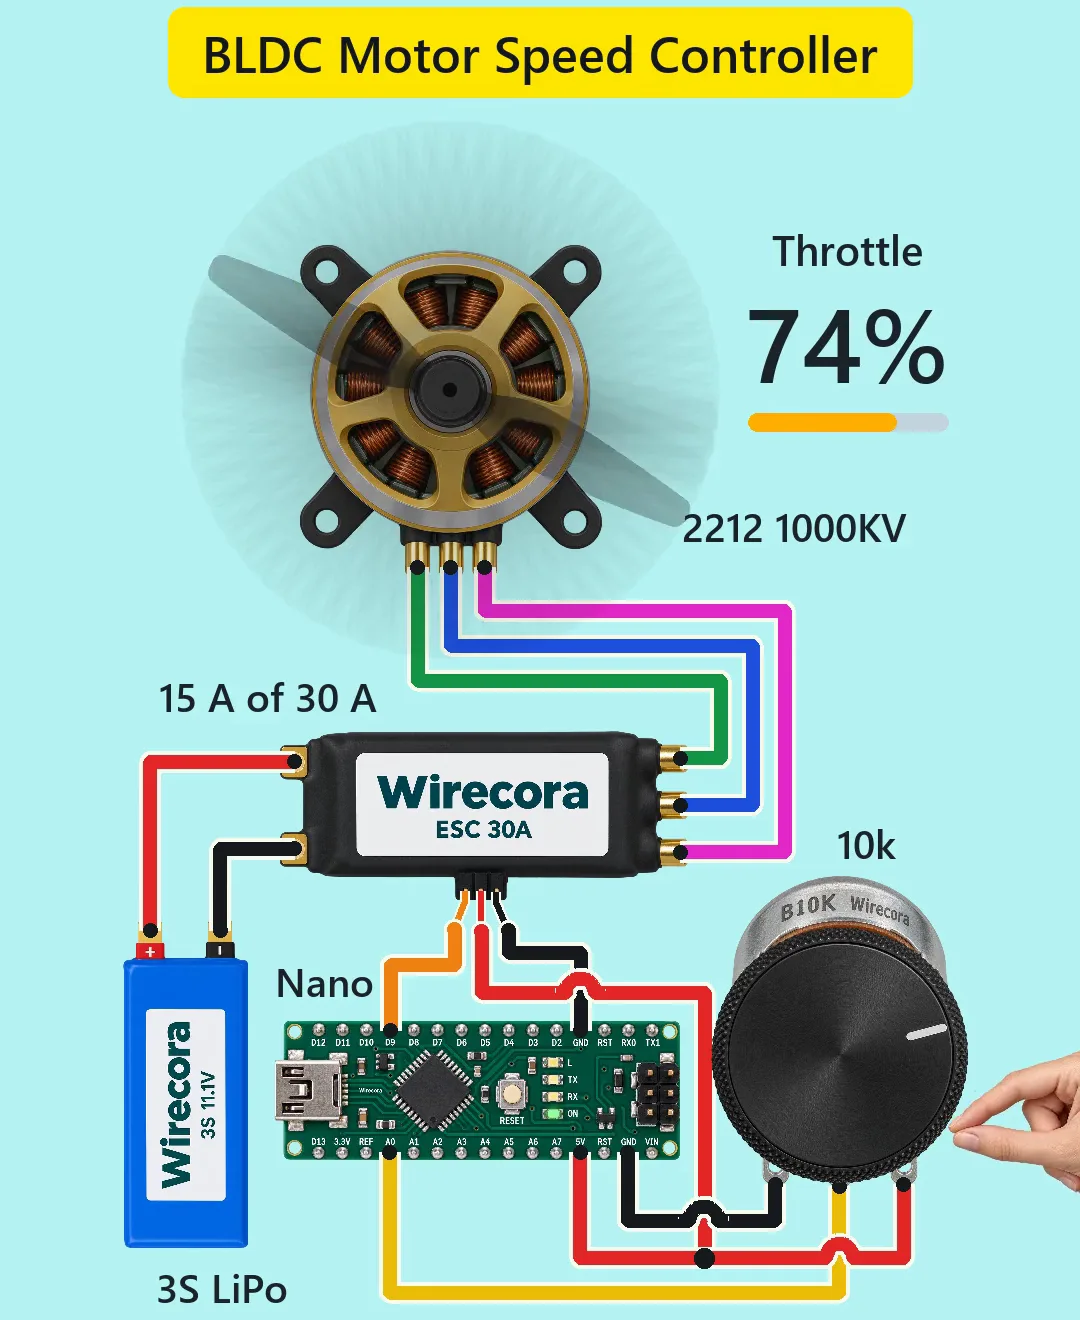
- LiPo plus and minus to the ESC's battery pads.
- The ESC's three motor wires to the motor's three wires, in any order.
- ESC signal lead: signal wire to Nano D9, +5 V (the middle red wire, from the BEC) to the Nano 5V pin, ground to a Nano GND.
- Pot: one end to 5V, the other end to GND, the middle pin (wiper) to A0.
- There is one battery and no USB: the ESC's BEC powers the Nano.
Before you power it: Take the propeller off for bench tests and keep clear. Turn the knob fully down before connecting the battery. A LiPo battery can start a fire if shorted or damaged: handle it carefully.
Parts list
- 2212 1000KV brushless outrunner motor (typical part, assumed)
- 10 inch two-blade propeller (assumed)
- 30 A ESC with a 5 V BEC (the BEC powers the Nano)
- 3S 2200 mAh 25C LiPo battery (assumed)
- Arduino Nano
- 10 k linear potentiometer (B10K) with a knob
Wiring, step by step
- LiPo plus and minus to the ESC's battery pads.
- The ESC's three motor wires to the motor's three wires, in any order. Swapping any two reverses the motor.
- ESC signal lead: signal wire to Nano D9, +5 V (the middle red wire, from the BEC) to the Nano 5V pin, ground to a Nano GND.
- Pot: one end to 5V, the other end to GND, the middle pin (wiper) to A0.
- There is one battery and no USB: the ESC's BEC powers the Nano. Do not plug in USB at the same time.
How it works
- The Nano reads the pot on A0 and sends a servo-style signal on D9: a pulse of 1000 microseconds means stop and 2000 microseconds means full throttle.
- The ESC reads that pulse and drives the three motor wires in turn, so the motor speed follows the knob. The Throttle readout is (pulse width minus 1000) divided by 10, in percent.
- The sketch arms the ESC by sending 1000 microseconds for two seconds at start. Some ESCs need calibrating to the 1000 to 2000 microsecond range: follow the ESC's manual if yours does not arm.
- Full throttle draws about 12 to 15 A with a 10 inch prop, about half the ESC's 30 A rating and well inside the battery's 55 A. The BEC load is only the Nano, about 19 mA.
- The motor is rated about 12 A, so run full throttle in short bursts only.
The code: drone_motor_knob.ino
The Arduino code for this circuit is in the Wirecora Discord, in the channel #arduino-code (owner’s choice, 14 October 2026: the code lives where you can ask about it). It is a plain .ino file you can download there.
The sketch from the Short's description; it has not been run on a real board yet. Take the propeller off before testing. It uses the Servo library that comes with the Arduino IDE.
What the video simplifies
- The blur stands for about 130 turns a second (about 8,000 rpm loaded; 11,100 rpm with no propeller). The blade seen over the blur is drawn slower.
- The spin-up delay is illustrative, and the hand turns the knob faster than usual.
- The propeller is drawn smaller than a real 10 inch prop, and the motor bell is drawn still.
- The parts are drawn at different scales.
- The sound is synthesised and silent at full speed, where a real motor is loudest.
- The motor, propeller and battery are typical parts, assumed. The ESC's throttle range is assumed calibrated to 1000 to 2000 microseconds.
- Checked by simulation and datasheets only, not built.
You found this by searching. Here's the whole path.
- Read how it works
- See it work
- Build it
- Show it
Thirty seconds of video shows the circuit doing its job.
Take the propeller off for bench tests and keep clear. Turn the knob fully down before connecting the battery. A LiPo battery can start a fire if shorted or damaged: handle it carefully.
Built it, or stuck halfway? Post a photo in the Wirecora Discord. Questions get an answer every day.
What to build next
 Same Arduino + motorFloor mopping robot: Arduino Nano, HC-SR04 and L298NThe robot drives over a hard floor, mists a little water and wipes it with a cloth pad.
 Next step: adds a buzzerDaily pill dispenserAt 8:00 a chime sounds, the wheel turns one slot and a single white tablet drops into the cup.
 Something new: a light sensorLaser tripwire alarmA red laser shines on a light sensor and the buzzer stays quiet.